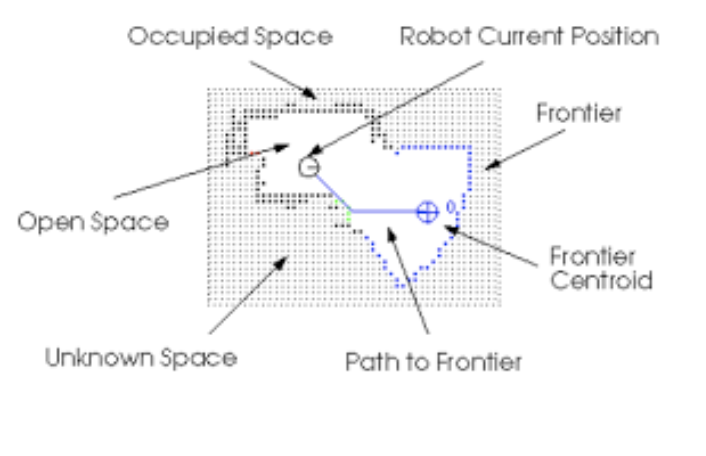
Initial testing with 4 robots – identified initialization issue
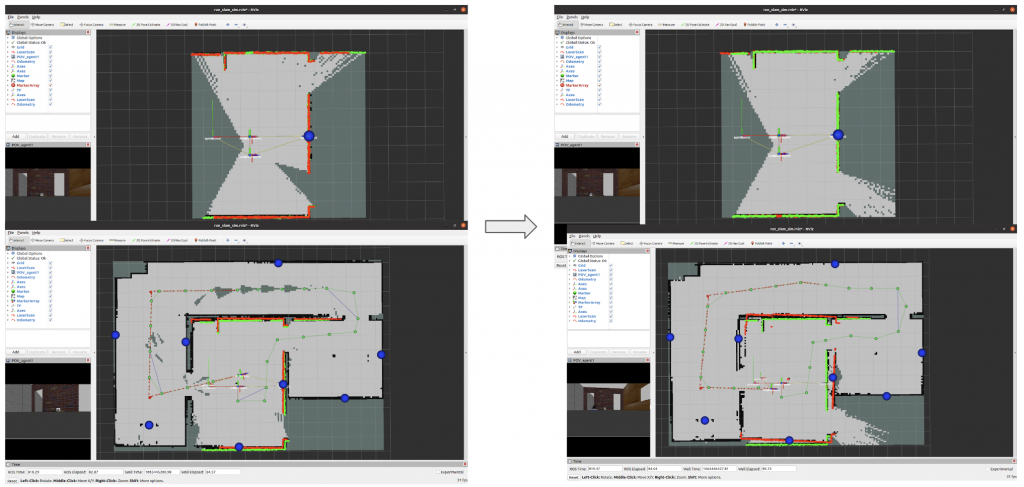
Modified Ray Casting behaviour to fill in all free areas
Navigation
Hardware testing for Lazy Traffic Controller
Tune the controller velocity calculation frequency to the execution frequency of the robots
Since differential drive robots don’t immediately achieve commanded velocity, use feedback velocity (calculated from change in position of the robot) for velocity obstacles calculation
Addition of new term in cost function while scoring velocities to reduce oscillations