Spring Gantt Chart

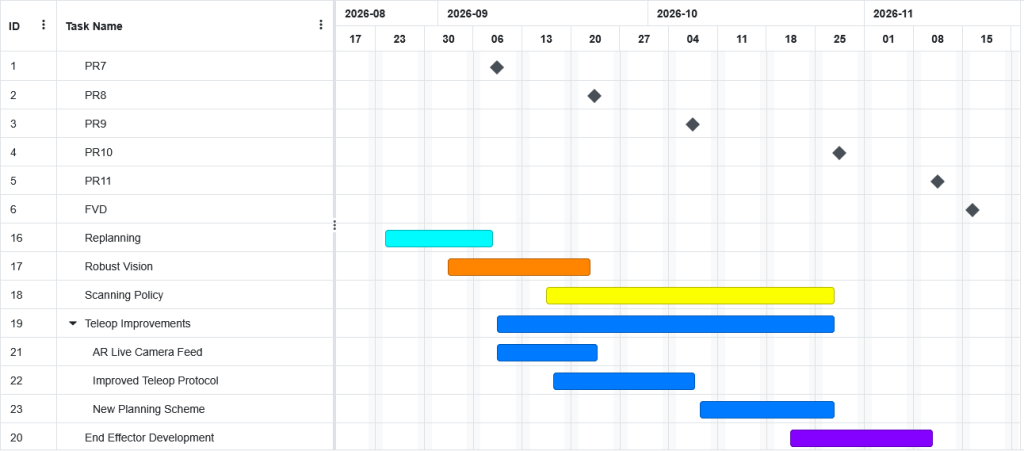
Fall Gantt Chart
Presenters
Spring:
Sensors and Motors Lab: Shubh Jain
PR01: Aayush Agrawal
PR02: Shreenabh Agrawal
PR03: Gabriel Zaragoza
PR04: Shubh Jain
Fall:
PR07: Shubh Jain
PR08: Gabriel Zaragoza
PR09: Shreenabh Agrawal
PR10: Shubh Jain
PR11: Gabriel Zaragoza
Test Plan
Parts List
Our main spending for the project:
Subsystem Hardware: $440
- Logitech Muse Spatial Controller, 2 Adafruit foot switches, 2 Raspberry Pi Zero, Studio Lights + Stand
Software & Operations: $129
- Apple Developer License, surgery drape sheets
Provided by Sponsor/Past Teams
- KUKA LBR Med 7 Cobot, Apple Vision Pro headset, Polaris IR camera and tracker arrays, RTX 4070 workstation computer
Issues Log
Risk Management
| ID | Risk | Req. | Type | L | C | Mitigation |
|---|---|---|---|---|---|---|
| R1 | Registration accuracy below medical grade | PR1, PR6 | Technical | 0 | 4 | Atracsys ground truth setup operational; YOLO 2D pipeline replaces SAM; ICP with iterative refinement |
| R2 | Mis-drill of bone by robot end effector | PR5, NFR2 | Safety | 2 | 5 | Dry-run cycles without tool rotation; virtual safe zones + geofencing; force monitoring; physical + software E-stop |
| R3 | S+N drill handpiece incompatible with KUKA | FR3.1 | Technical | 3 | 4 | Software integration first; fallback to simple drill with robot pose/feed control |
| R4 | Teleoperation latency exceeds safe threshold | PR9, FR4.1 | Technical | 3 | 4 | Local network testing first; command buffering protocol; latency monitoring with auto-halt |
| R5 | System integration delays across subsystems | NFR1 | Schedule | 0 | 4 | Defined ROS2 interfaces; weekly integration checkpoints; parallel development tracks |
| R6 | IR tracking drift during extended procedure | PR1, PR3 | Technical | 0 | 4 | EKF smoothing in pipeline; periodic re-calibration checks; Atracsys as backup reference |
| R7 | Budget overrun from bone model consumption | — | Cost | 3 | 3 | Moldable surrogates for iterative testing; anatomic models reserved for final validation |
| R8 | Drilling reliability under load – force, torque | FR6 | Technical | 3 | 4 | T11 bench characterization w/ force+torque telemetry; T12 force-monitored drilling on phantom; abort thresholds wired to software E-stop. |
| R9 | NFR-05 compliance gap | NFR5 | Technical | 3 | 2 | T15 compliance-mapping checklist. Documentation only — not full certification (out of scope for academic project). |
| R10 | Cross-coordinate-frame bug recurrence with new EE | FR2 | Technical | 2 | 3 | Static transform publisher with explicit checks; unit tests for each transform; behaviour tree for state management. |
| R11 | Team capacity decrease | N/A | N/A | 4 | 4 | Re-scope discuss with Smith & Nephew Move repos to team org. |
| R12 | Knowledge continuity | N/A | N/A | 3 | 4 | Finalise Knowledge transfer document & context |
| R13 | New point cloud model decreases average accuracy | PR15 | Technical | 2 | 3 | retain original pre-defined trajectory in system as fallback |
| R14 | End effector damage | PR19 | Technical | 4 | 2 | manufacture more than one, design for pen replacement |
| R15 | AVP can’t efficiently render custom models | PR17 | Technical | 3 | 4 | increase focus on improving network pipeline |
| L = Likelihood (1-5), C = Consequence (1-5). Scale: 1 = lowest, 5 = highest. |
Risk Matrix
