
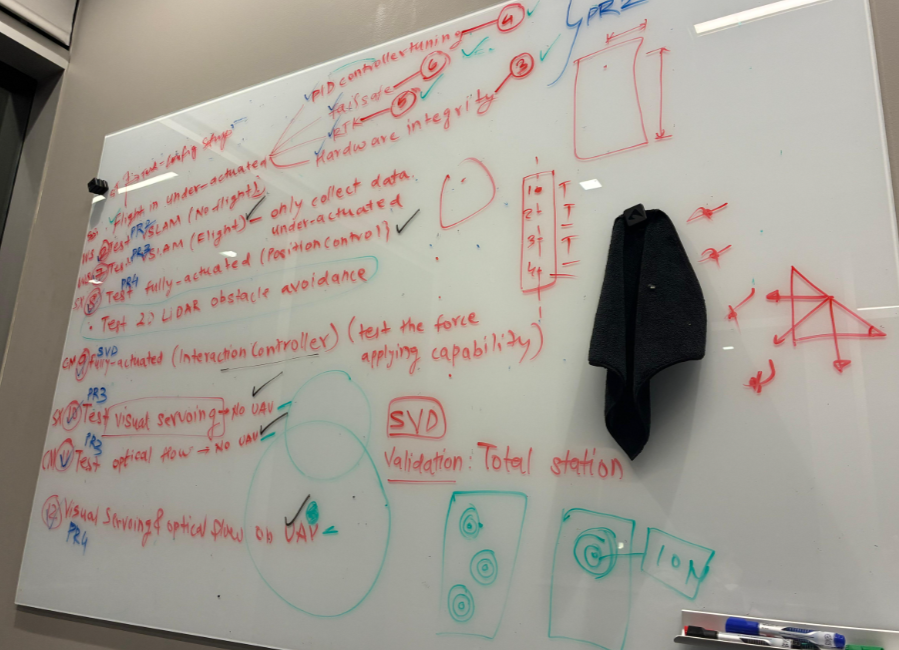
Design Brainstorming

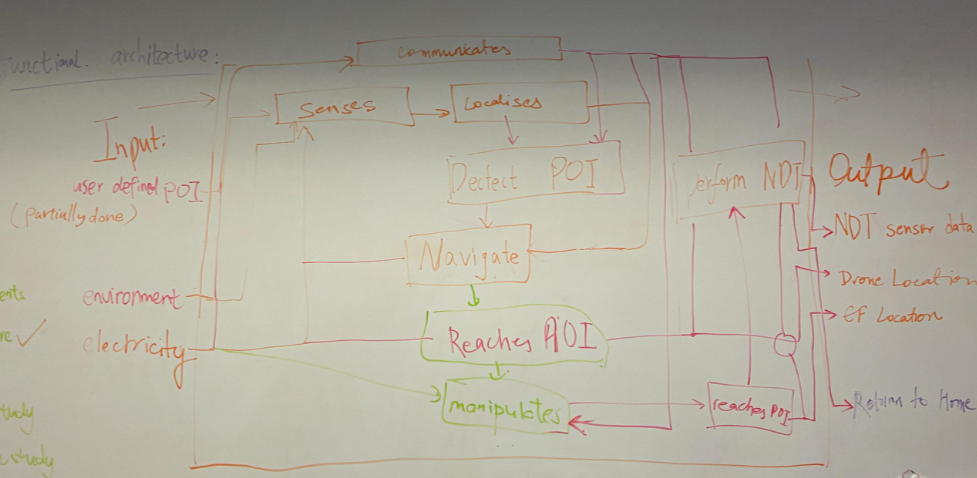
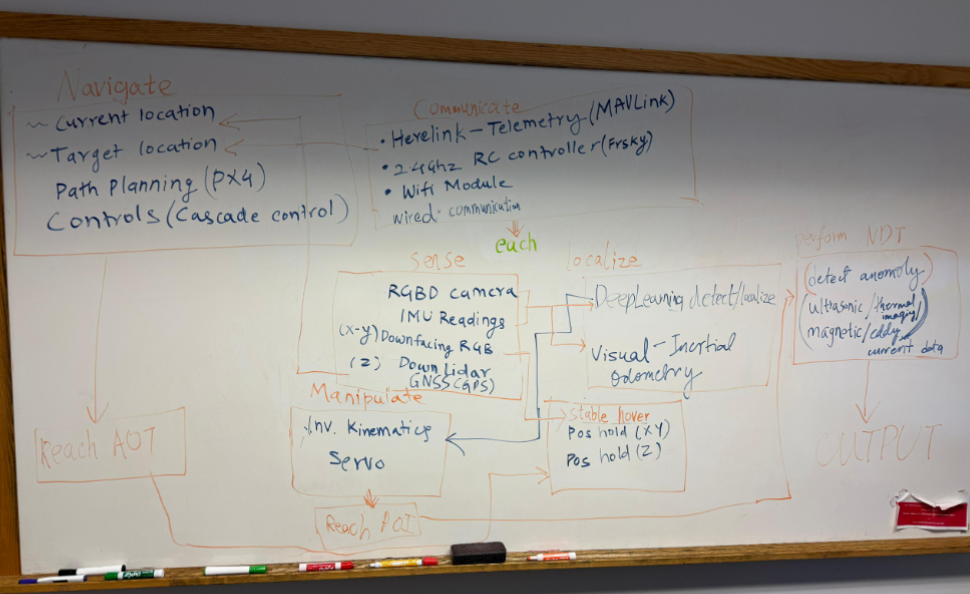
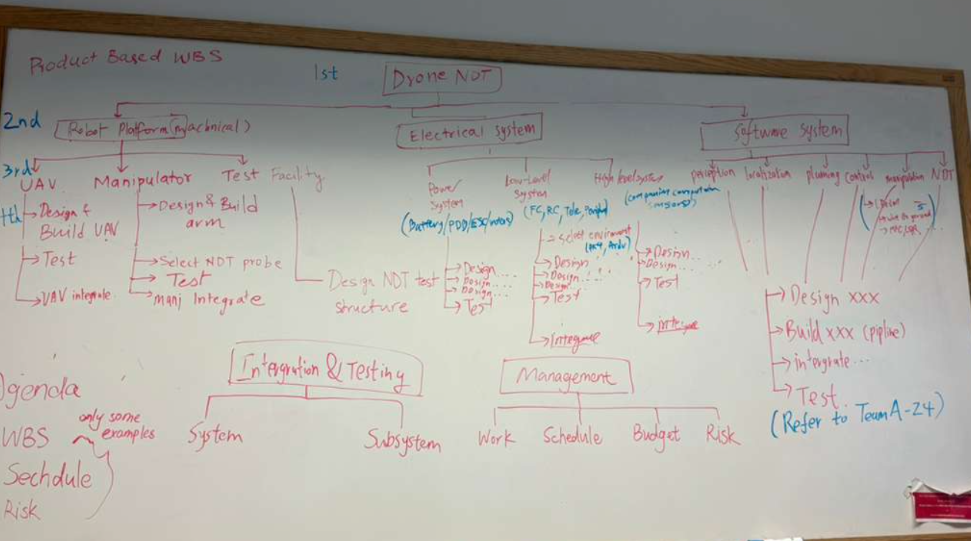
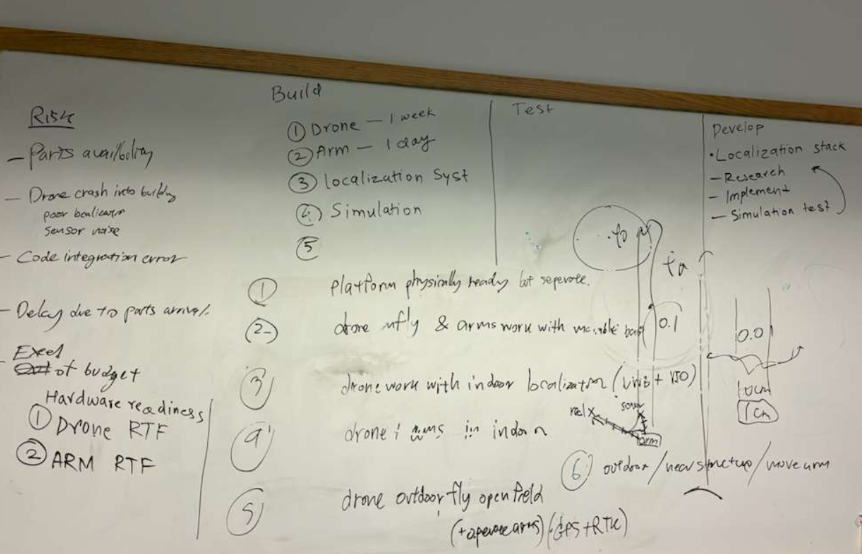
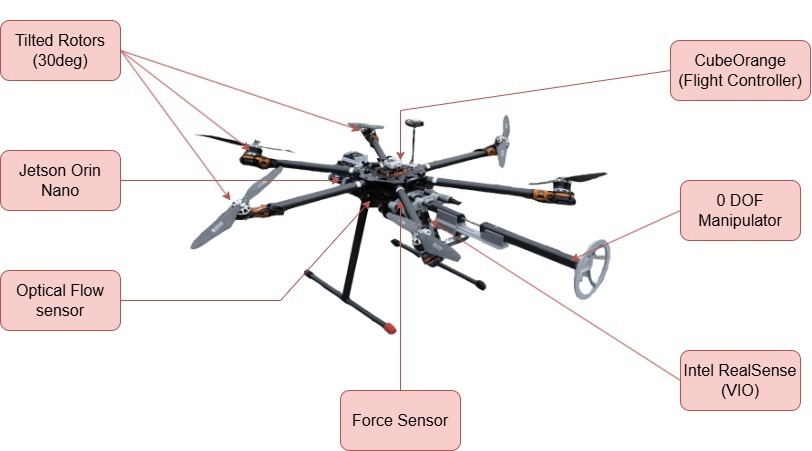
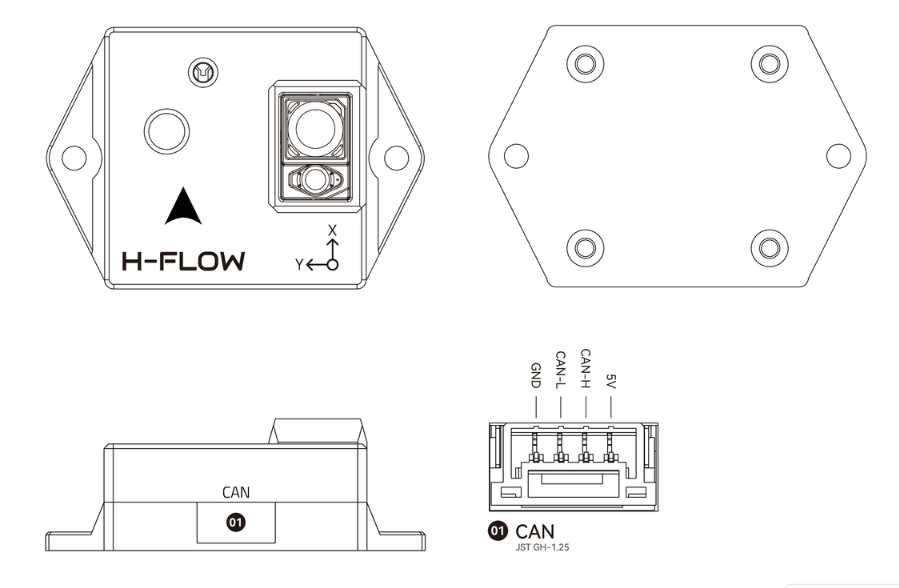
Drawings, Schematics, and Datasheets
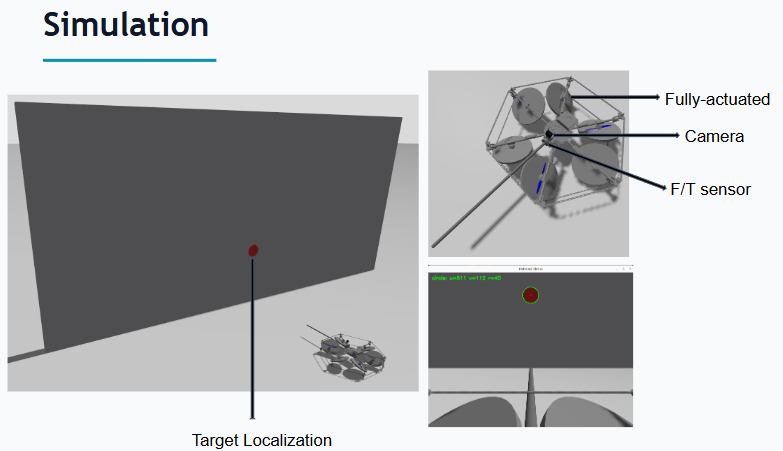



Component Testing & Experiment Results
- Optical Flow Test Rig:
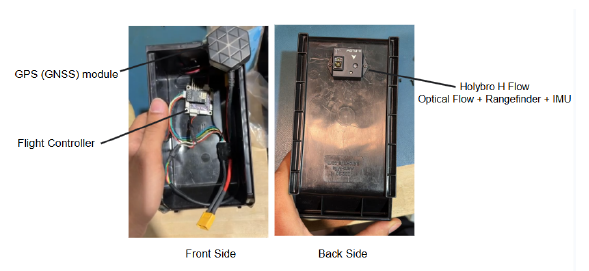
Designed and executed a structured benchmarking suite comprising five tests:
- GPS degradation analysis to identify thresholds where EKF2 rejects GPS and transitions to optical
flow. - Flow-only localization to evaluate drift and position-hold accuracy in complete GPS denial.
- Sensor transition testing (GPS-Flow) to ensure smooth, stable estimator switching without position
jumps. - Surface and height sensitivity analysis to characterize optical flow quality across realistic structural
materials and operating distances. - Disturbance rejection testing to assess estimator robustness under vibration and contact-like impulses.
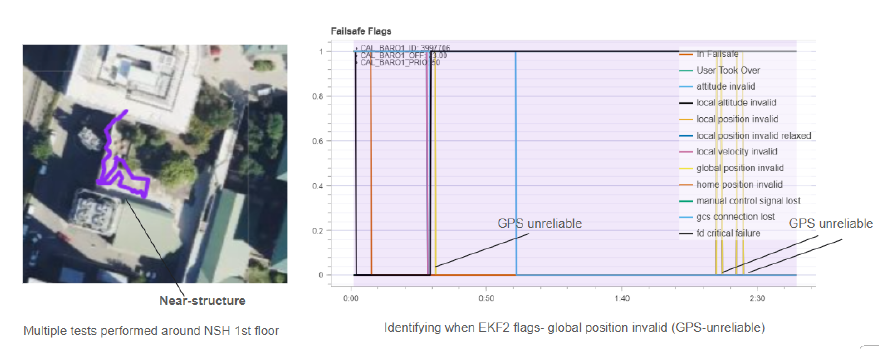
Multiple tests were conducted by moving the optical flow subsystem around NSH 1st floor, including
close to structures. The objective was to analyze flight logs to identify instances where EKF2 flagged
the global position as invalid (indicating unreliable GPS, especially near structures). During these periods,
the estimator relied solely on optical flow for velocity and altitude estimation and it was accurate.
This behavior was validated by examining velocity plots at corresponding timestamps, which remained
smooth—confirming proper EKF2 sensor fusion during GPS-denied conditions.
Software
Presentations
Conceptual Design Review document
Individual Lab Reports (ILRs)
| Chenyang Mao | Shunxuan Wang | Shubha Tanaya | Weerachai Sangiumpaisankij | Shubham Saboo |
| ILR1 | ILR1 | ILR1 | ILR1 | ILR1 |
| ILR2 | ILR2 | ILR2 | ILR2 | ILR2 |
| ILR3 | ILR3 | ILR3 | ILR3 | ILR3 |
| ILR4 | ILR4 | ILR4 | ILR4 | ILR4 |
| ILR5 | ILR5 | ILR5 | ILR5 | ILR5 |
| ILR6 | ILR6 | ILR6 | ILR6 | ILR6 |
| ILR7 | ILR7 | ILR7 | ILR7 | ILR7 |
| ILR8 | ILR8 | ILR8 | ILR8 | ILR8 |
| ILR9 | ILR9 | ILR9 | ILR9 | |
| ILR10 | ILR10 | ILR10 | ILR10 |