
System Design
System Requirements
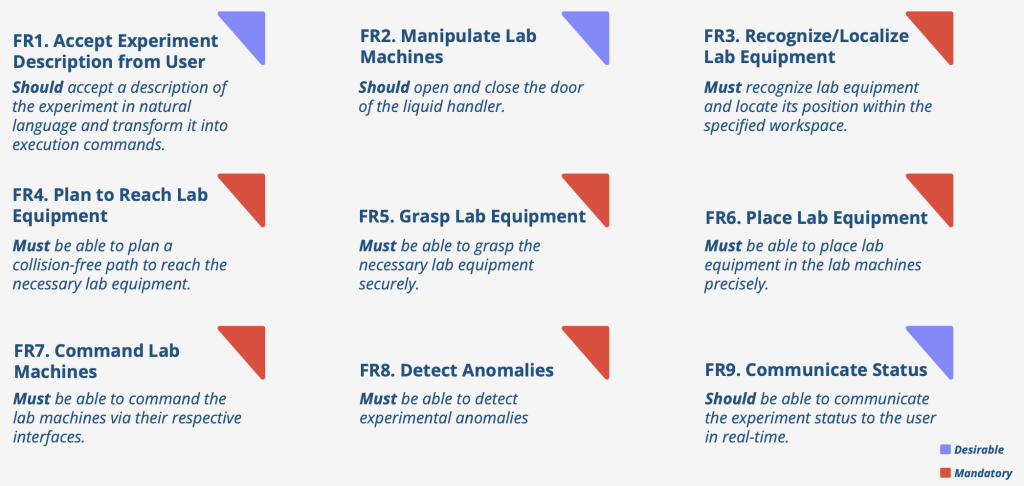
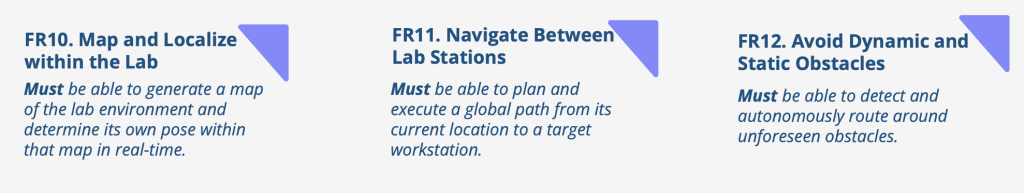
Functional Requirements
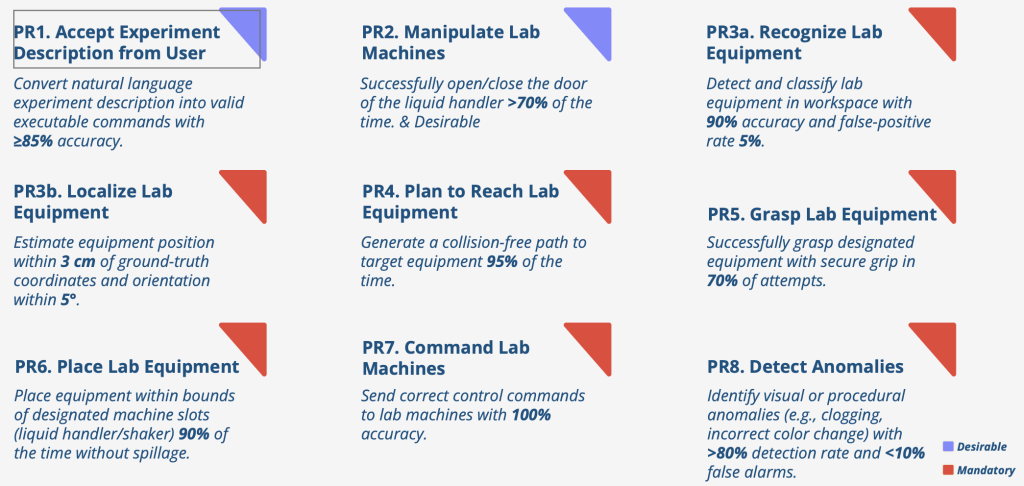
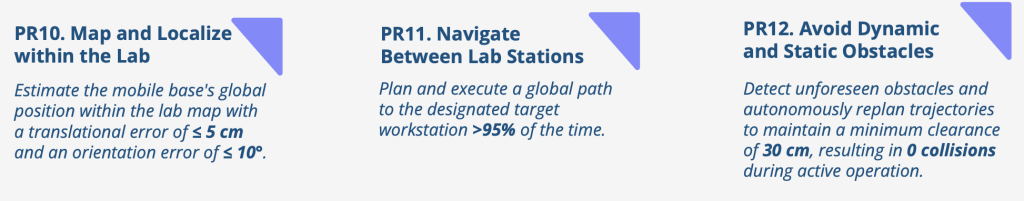
Performance Requirements
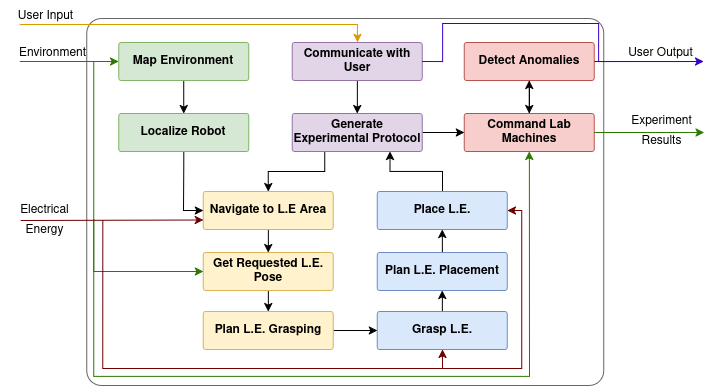
Functional Architecture
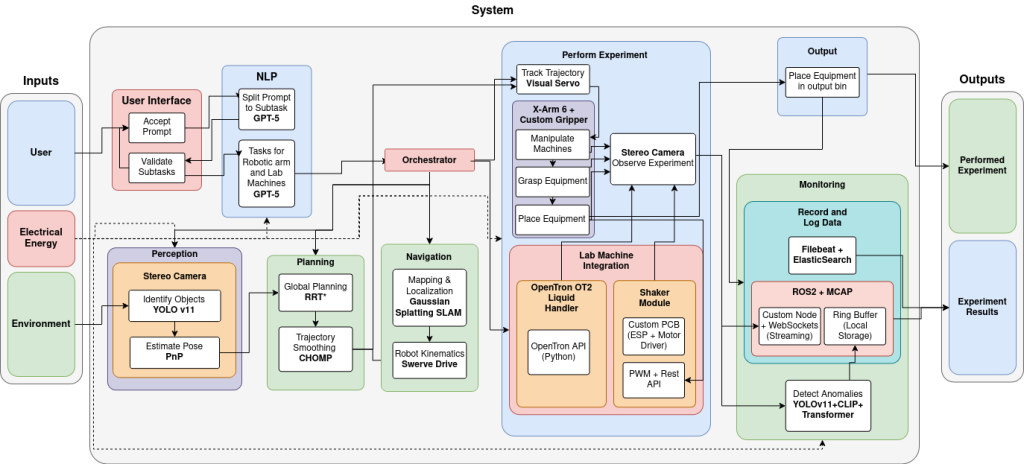
Cyberphysical Architecture
System Design Description
Our system will be composed of a mobile base and a 6 degree of freedom manipulator. The manipulator will have a custom designed gripper to be able to interact with lab equipment properly. The mobile base will contain four motors, two LiDAR sensors, an IMU, two ZED X Stereo cameras, and onboard compute (Jetson Xavier and Thor). It will have its own battery pack to power all of the different system components.