PCB Information
PCB Description
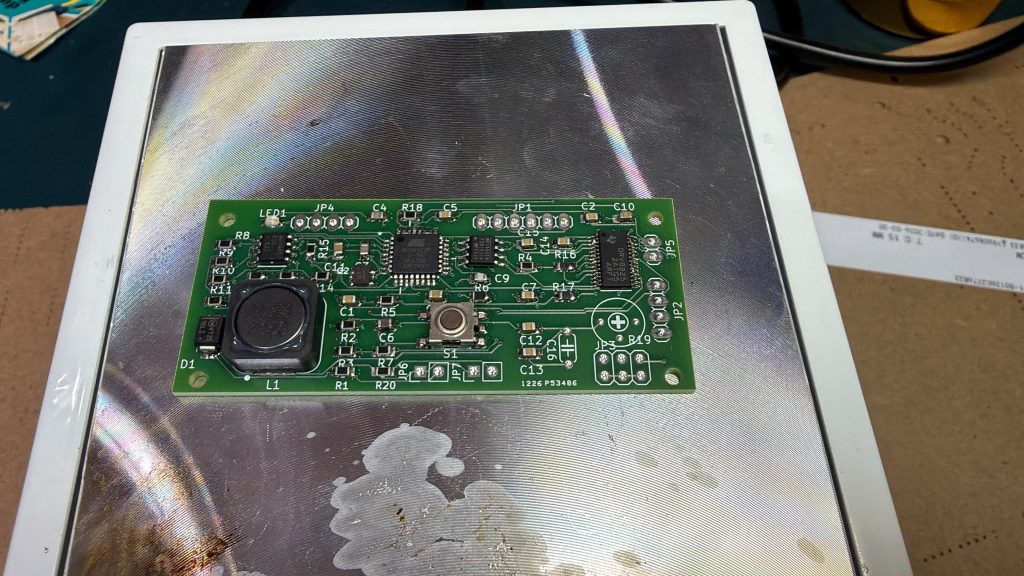
This custom-designed PCB serves as the central control and power management unit for our robotic gripper system, enabling reliable actuation, communication, and embedded control within a compact footprint.
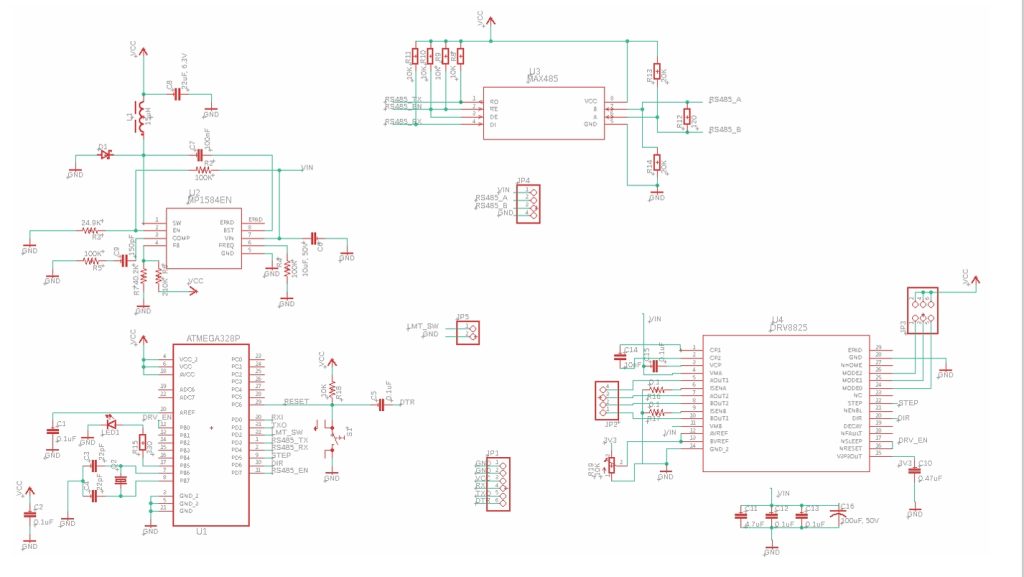
Powered directly from the xArm6’s 24V auxiliary output, the board efficiently distributes power across both mechanical and logic subsystems. A high-performance buck converter (MP1584EN) steps down the 24V input to a stable 5V rail, supporting onboard electronics including the ATmega328P microcontroller, RS485 communication interface, and status indicators.
For motion control, the PCB integrates a DRV8825 stepper motor driver, capable of handling the NEMA 17 motor used in the gripper mechanism. The system operates well within safe thermal and electrical limits, with experimentally validated current consumption (~150 mA for the motor and ~100 mA peak for logic), ensuring both efficiency and long-term reliability.
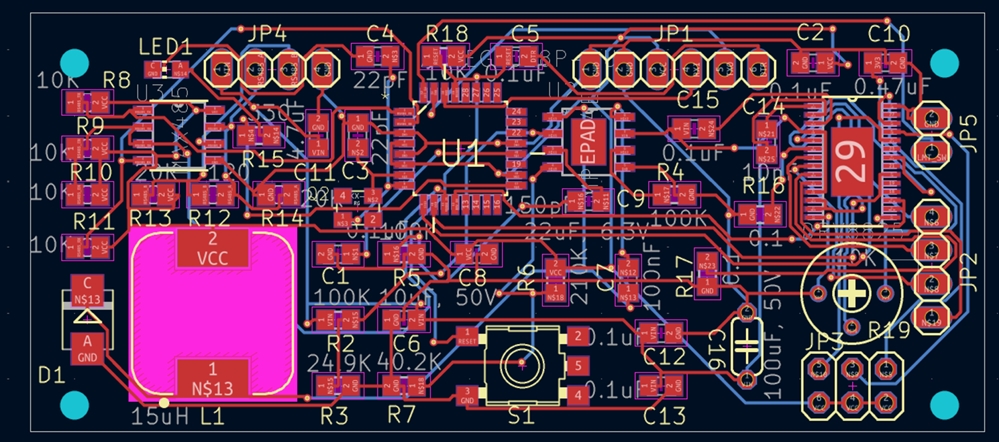
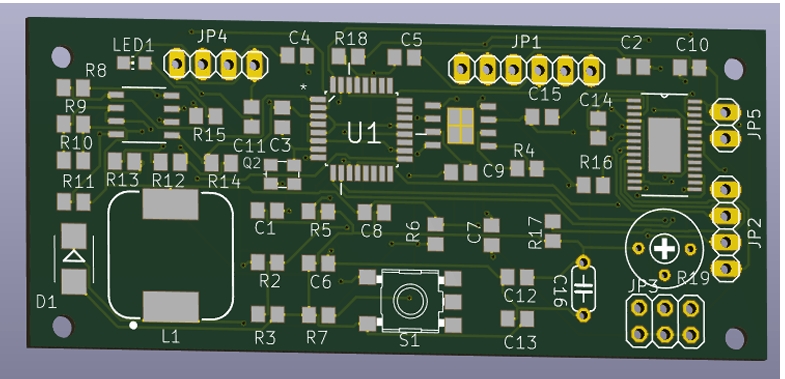
The board layout, designed in KiCAD, emphasizes signal integrity and thermal performance. Key design features include:
- Optimized trace routing with 10 mil width for power handling
- Large ground planes and thermal vias for passive heat dissipation
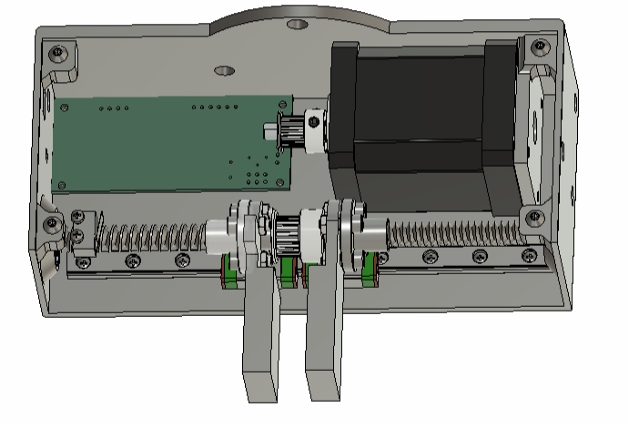
- Compact form factor tailored for seamless integration within the gripper housing
With a total worst-case current draw of approximately 275 mA, well below the available supply, the PCB provides a robust and scalable platform for embedded robotic control
Schematic
Layout
Bill of Materials
Related Figures
Mechanical Designs