Electrical
Wiring diagrams
The AXilles electrical architecture is designed for high-performance robotic control, integrating a Jetson Orin Nano for high-level processing with the AK-80-9 high-torque actuator.
Schematic Circuit Diagrams
Central to the exoskeleton is a custom-designed Power Distribution PCB. This board manages the 24V battery input and splits it into three specialized rails to protect sensitive electronics from the high-current demands of the motor.
Technical Documentation:
https://drive.google.com/file/d/1IMPjUEkLwpxbWVOxPBtZcafxWYswKFN1/view?usp=sharing

PCB Layout
Full Layout Overview
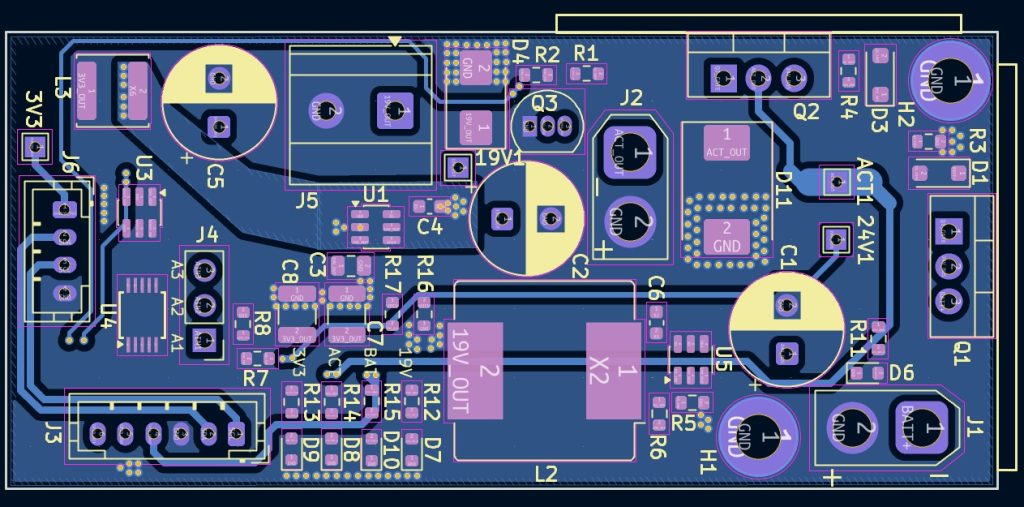
The complete layout integrates the high-current XT-60 and XT-30 connectors with a compact SOT-23 and SOT-223 footprint for the regulation suite. Component placement was optimized to minimize the loop area of the LMR51635 buck converter, reducing electromagnetic interference (EMI) across the entire system.
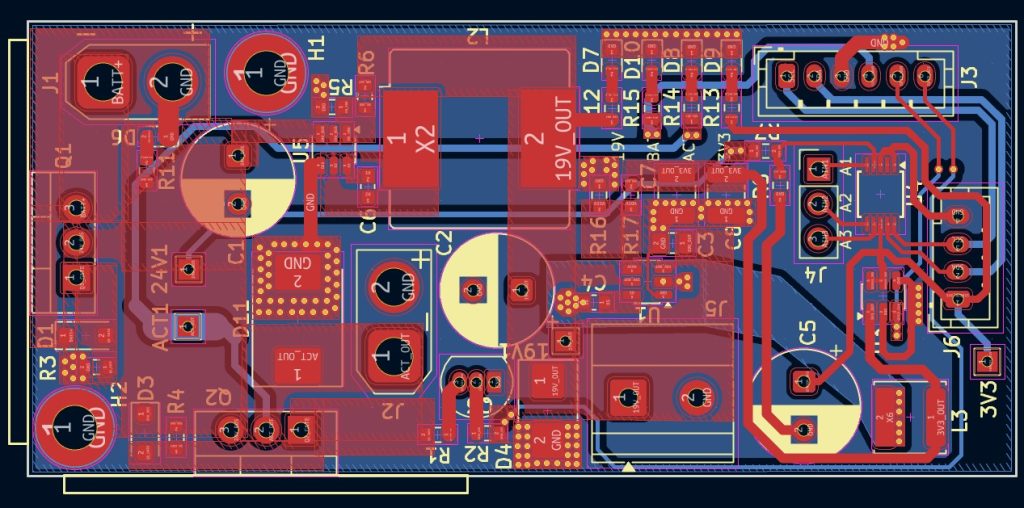
Top Layer
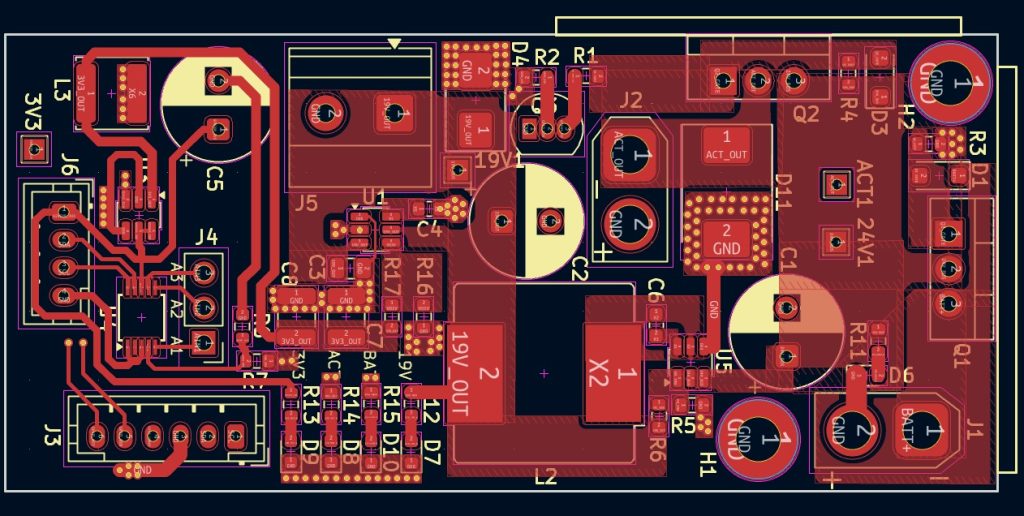
Bottom Layer

Datasheets
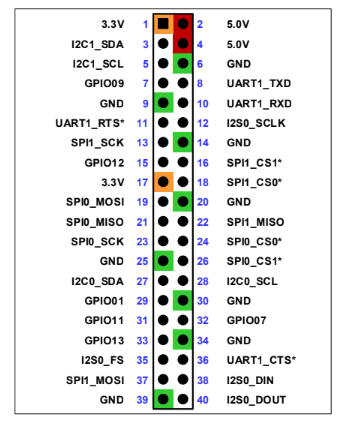
Nvidia Jetson Orin
AS5600
ADS1115
BNO085
CubeMars AK80-9 V3
Mechanical
The mechanical design of the AXilles exoskeleton focuses on a lightweight yet rigid frame capable of transferring high torque to the ankle joint. By utilizing precision-machined components and a modular architecture, we achieved a balance between user comfort and mechanical durability.
Drawings
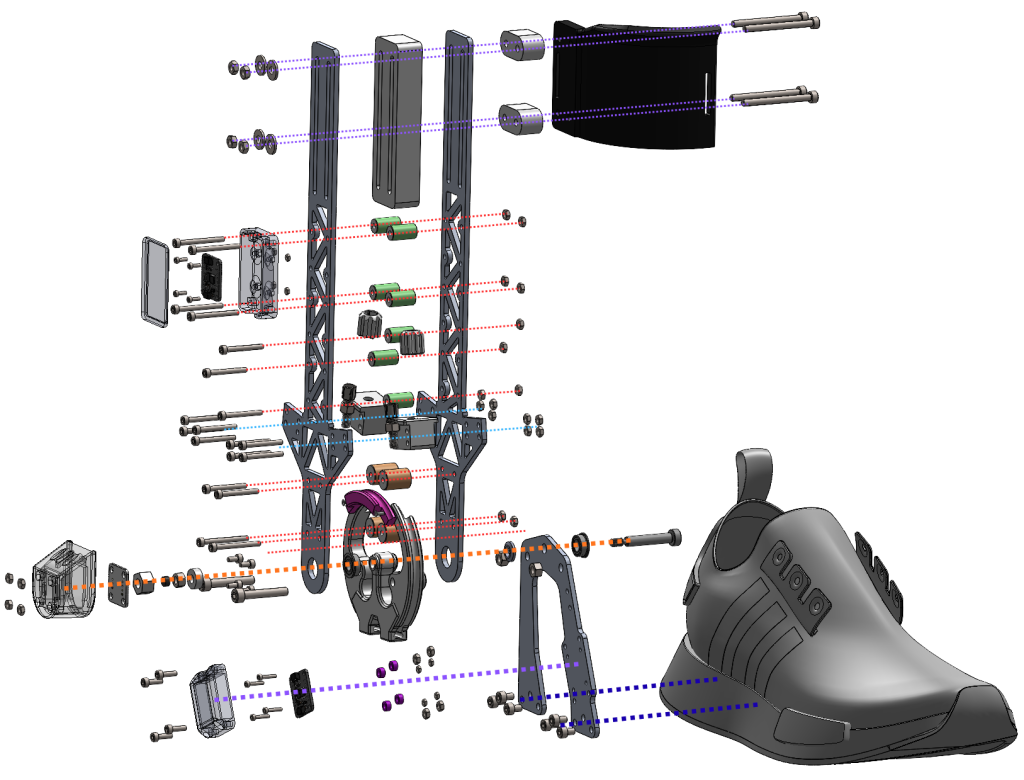
To illustrate the complexity of the assembly, the following exploded views highlight the integration of the actuator housing, force transmission mechanisms, and the ergonomic interface. This view provides a detailed look at the internal components, including the custom fasteners and alignment features that ensure smooth kinematic transitions.