Exoskeletons have been commonly associated with rehabilitation for people with disabilities or older adults. However, breaking this misconception, exoskeletons have several applications in the military, industrial and day to day activities, offering various forms of assistance and muscle amplification.
An ankle exoskeleton is capable of providing assistance or amplification only at the lower leg, but has tremendous effects on the energy consumed during walking, jogging or hiking, albeit the effects which may vary from individual to individual based on the user’s anthropomorphic data. However, the market for such an exoskeleton is still quite young as the demand of a such a device has not yet manifested on a large scale, mainly due to its cost and its value for cost. However, with reduction in cost of general production and advancement in robotic technologies, it may soon be a viable product.
For healthy individuals, exoskeletons can act as assistive devices that aim to reduce their energy expenditure as they go about performing their routine. Ideally, the exoskeleton interprets the intent of the user and provides corresponding assistance through appropriate torque generation that reduces the muscle load and correspondingly the fatigue. Our team, seeks to achieve this goal.
Through our capstone project, we aim to develop a robotic ankle exoskeleton that provides adaptive, real-time assistance for a wide range of activities. The main challenge is to design a control system capable of generalizing to various locomotion tasks, ensuring smooth and natural user experience in different environments. The exoskeleton’s control system will adapt to user-specific gait patterns, optimizing performance as users navigate different terrains and ambulate in diverse scenarios.
Use Case
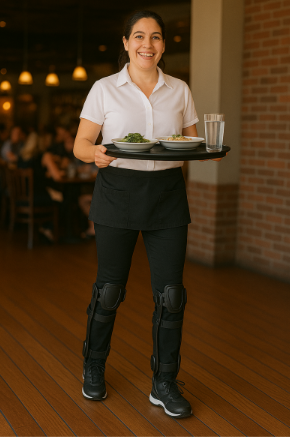
Maria, a 42-year-old server at a busy downtown restaurant, works 8-hour shifts where she walks an average of 12 miles per day carrying heavy trays and standing at customer tables. By the end of her shift, she experiences severe ankle and calf fatigue, often accompanied by foot drop symptoms that make her gait unsteady and increase her risk of tripping on the restaurant’s stairs.
Wearing the ankle exoskeleton during her shifts, Maria receives assistive dorsiflexion torque during the swing phase of each step, reducing the muscular effort required to lift her foot and preventing foot drop. The device’s gait-adaptive control automatically adjusts assistance based on her walking speed, providing more support when she’s rushing between tables and minimal assistance when she’s standing still taking orders.
Over a two-week trial period, Maria reports a 40% reduction in perceived leg fatigue at shift’s end, fewer stumbling incidents, and improved energy levels for her evening activities with family. The restaurant management observes decreased worker compensation claims and improved employee retention, demonstrating the exoskeleton’s potential to enhance workplace safety and job satisfaction in the hospitality industry.