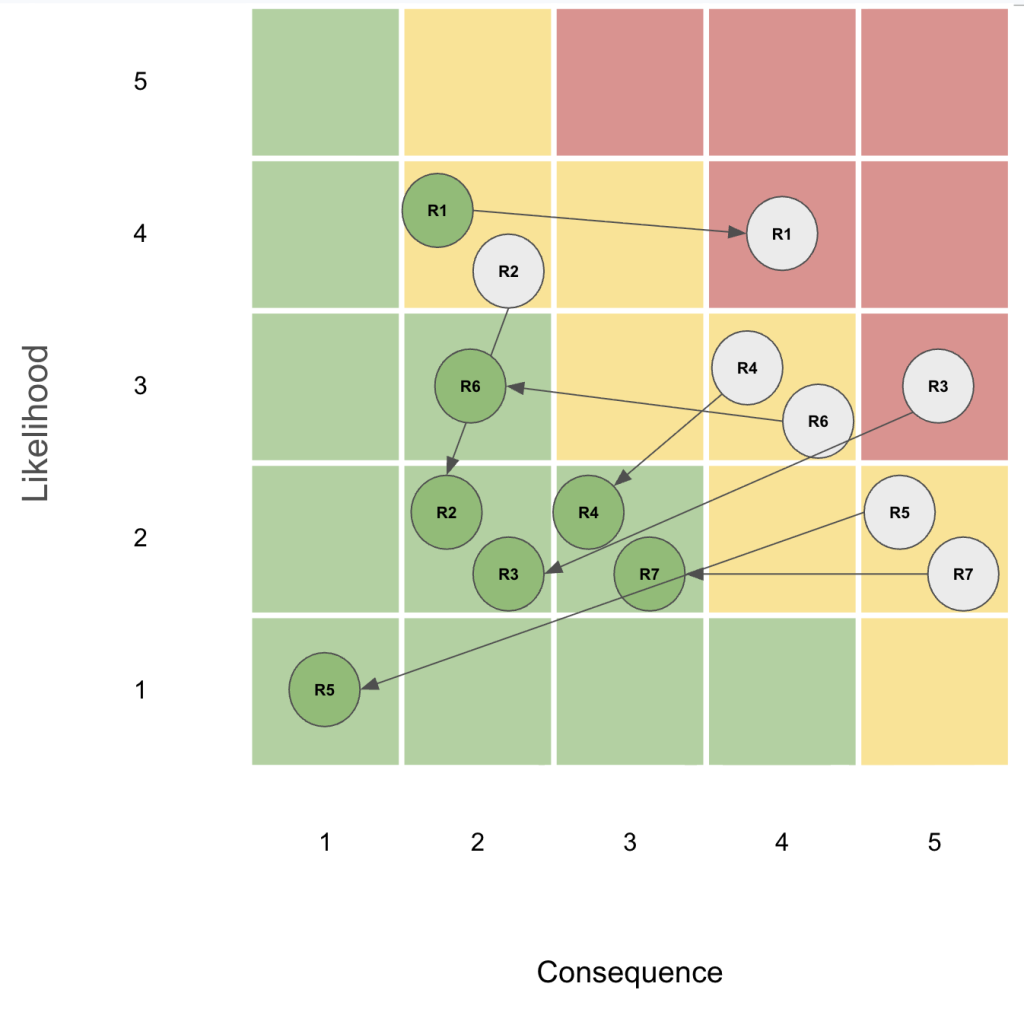
| ID | Risk | Req. | Type | L | C | Mitigation |
|---|---|---|---|---|---|---|
| R1 | Damage to Mechanical Parts | MF6-8, MN4 | Technical | 4 | 4 → 2 | 3D-print spare components, stock critical replacement parts, and design mechanical interfaces for fast swapping. |
| R2 | Hardware Compatibility Issue | MF6-8, MN4 | Technical, Integration | 3 → 2 | 4 → 2 |
– Use simulation and CAD to calculate CoM and avoid interference in CAD Assembly. – Mimic the weight of hardware system and payload on robot base and analyze performance. |
| R3 | Software Compatibility Issue | MF1-5, MN4 | Technical, Integration | 5 → 2 | 3 → 2 | Use Docker container to bridge the gap between different ROS and Ubuntu versions. |
| R4 | Insufficient Compute Power | MF1-12, MN4 | Technical | 3 → 2 | 4 → 3 |
– Use an FSM to run only the modules needed for the current robot state. – Optimize or offload compute-heavy tasks if performance is still insufficient. |
| R5 | Unable to Secure Testing Site | N/A | Schedule | 2 → 1 | 5 → 1 | Communicate early with park officials, and have backup test site ready. |
| R6 | Teammate Unavailability | N/A | Schedule | 3 | 4 → 2 | Maintain thorough documentation while development and testing. |
| R7 | Robot Collision while Traversing | MF1, MF5, MN2 | Safety | 2 | 5 → 3 | Always have two operators while robot is in operation with remote e-stop on hand. |