Fall 2026 Updates
Navigation Stack:
The navigation stack takes the Livox MID360 LiDAR and IMU into SLAM/localization and terrain analysis. A route planner runs Dijkstra routing over a saved terrain graph and outputs carrot waypoints; a local planner produces a collision-free path, a path follower converts it to velocity, and a command mux arbitrates between teleoperation and navigation before commands reach the Unitree interface.

Multi-Floor Mapping (Elevator-LIO):
Arise-SLAM could not map across floors because of IMU drift during the elevator ride, so it was replaced with Elevator-LIO for state estimation. Elevator-LIO maps across floors, but its activation condition for IMU correction is still simple and may miss the moment of entering the elevator.

Relocalization:
Relocalization against the saved map was added using GICP (Generalized Iterative Closest Point). In testing, the robot successfully relocalized itself with a structure score of 0.97.

Base Servoing Improvements:
Base servoing, a risk identified at the Critical Design Review, was improved by calibrating the IMU, removing lateral velocity, and switching to a non-holonomic planner. The robot now navigates to and from the elevator autonomously.
Open issues: the local planner sometimes produces poor locomotion plans, low locomotion precision can leave the button out of view, and a stiffer left ankle makes waypoints harder to track.
Spring 2026
Base Visual Servoing:
The visual servoing pipeline moves the robot’s base to an approach pose in front of a detected button panel, closing the loop from perception to robot motion. A pose filtering node applies moving-average smoothing and outlier rejection to the raw tracked pose, and the core Position-Based Visual Servoing (PBVS) node computes an approach goal by retracting along the surface normal by a configurable distance. It then sends this goal to the local movement
module, which drives the robot to the target. The robot can detect a button panel, filter the noisy pose estimate, compute a stable approach position,
and drive toward it — all without manual waypoints.
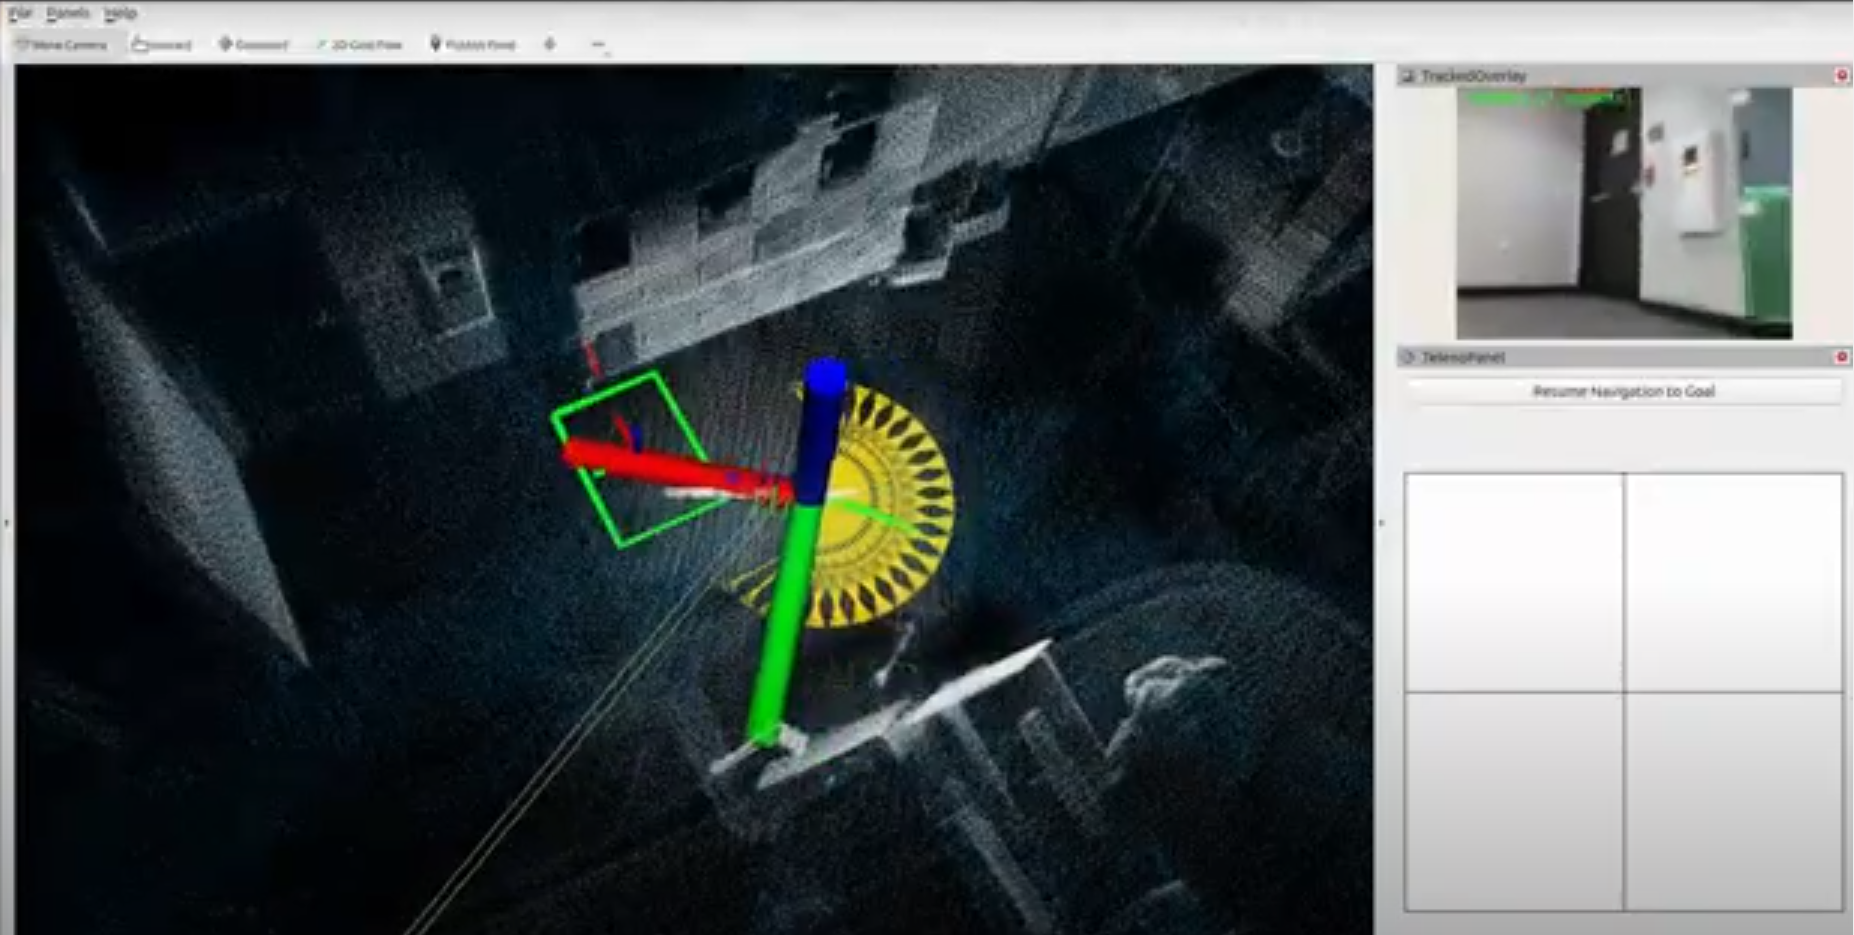
Fig: Robot Navigating to a Shelf
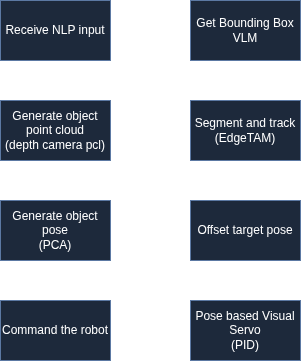
Fig: Visual servo base pipeline.